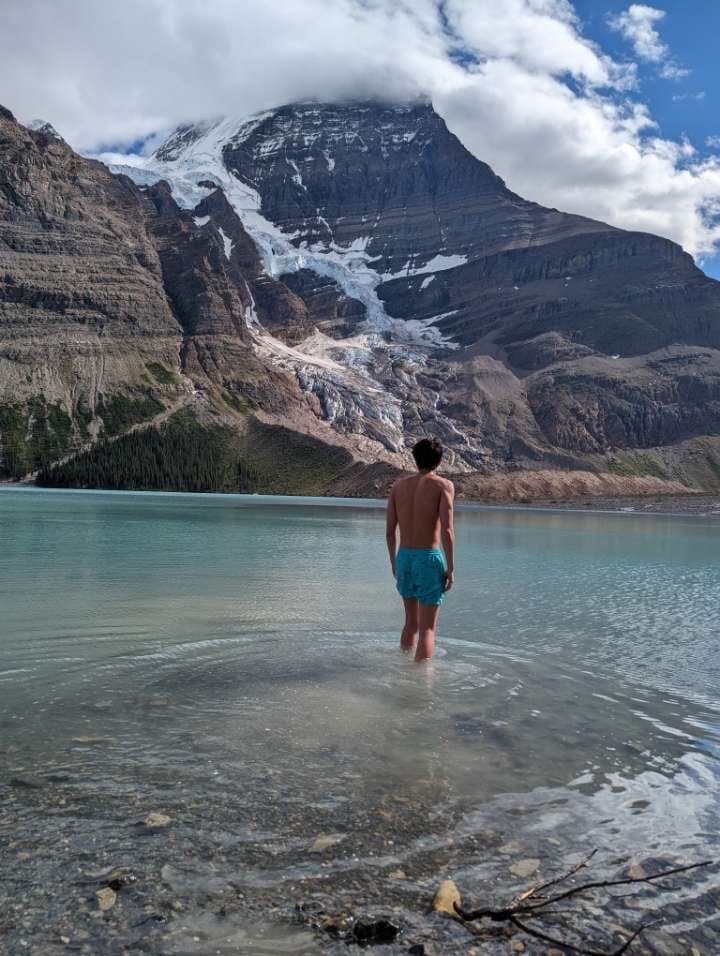
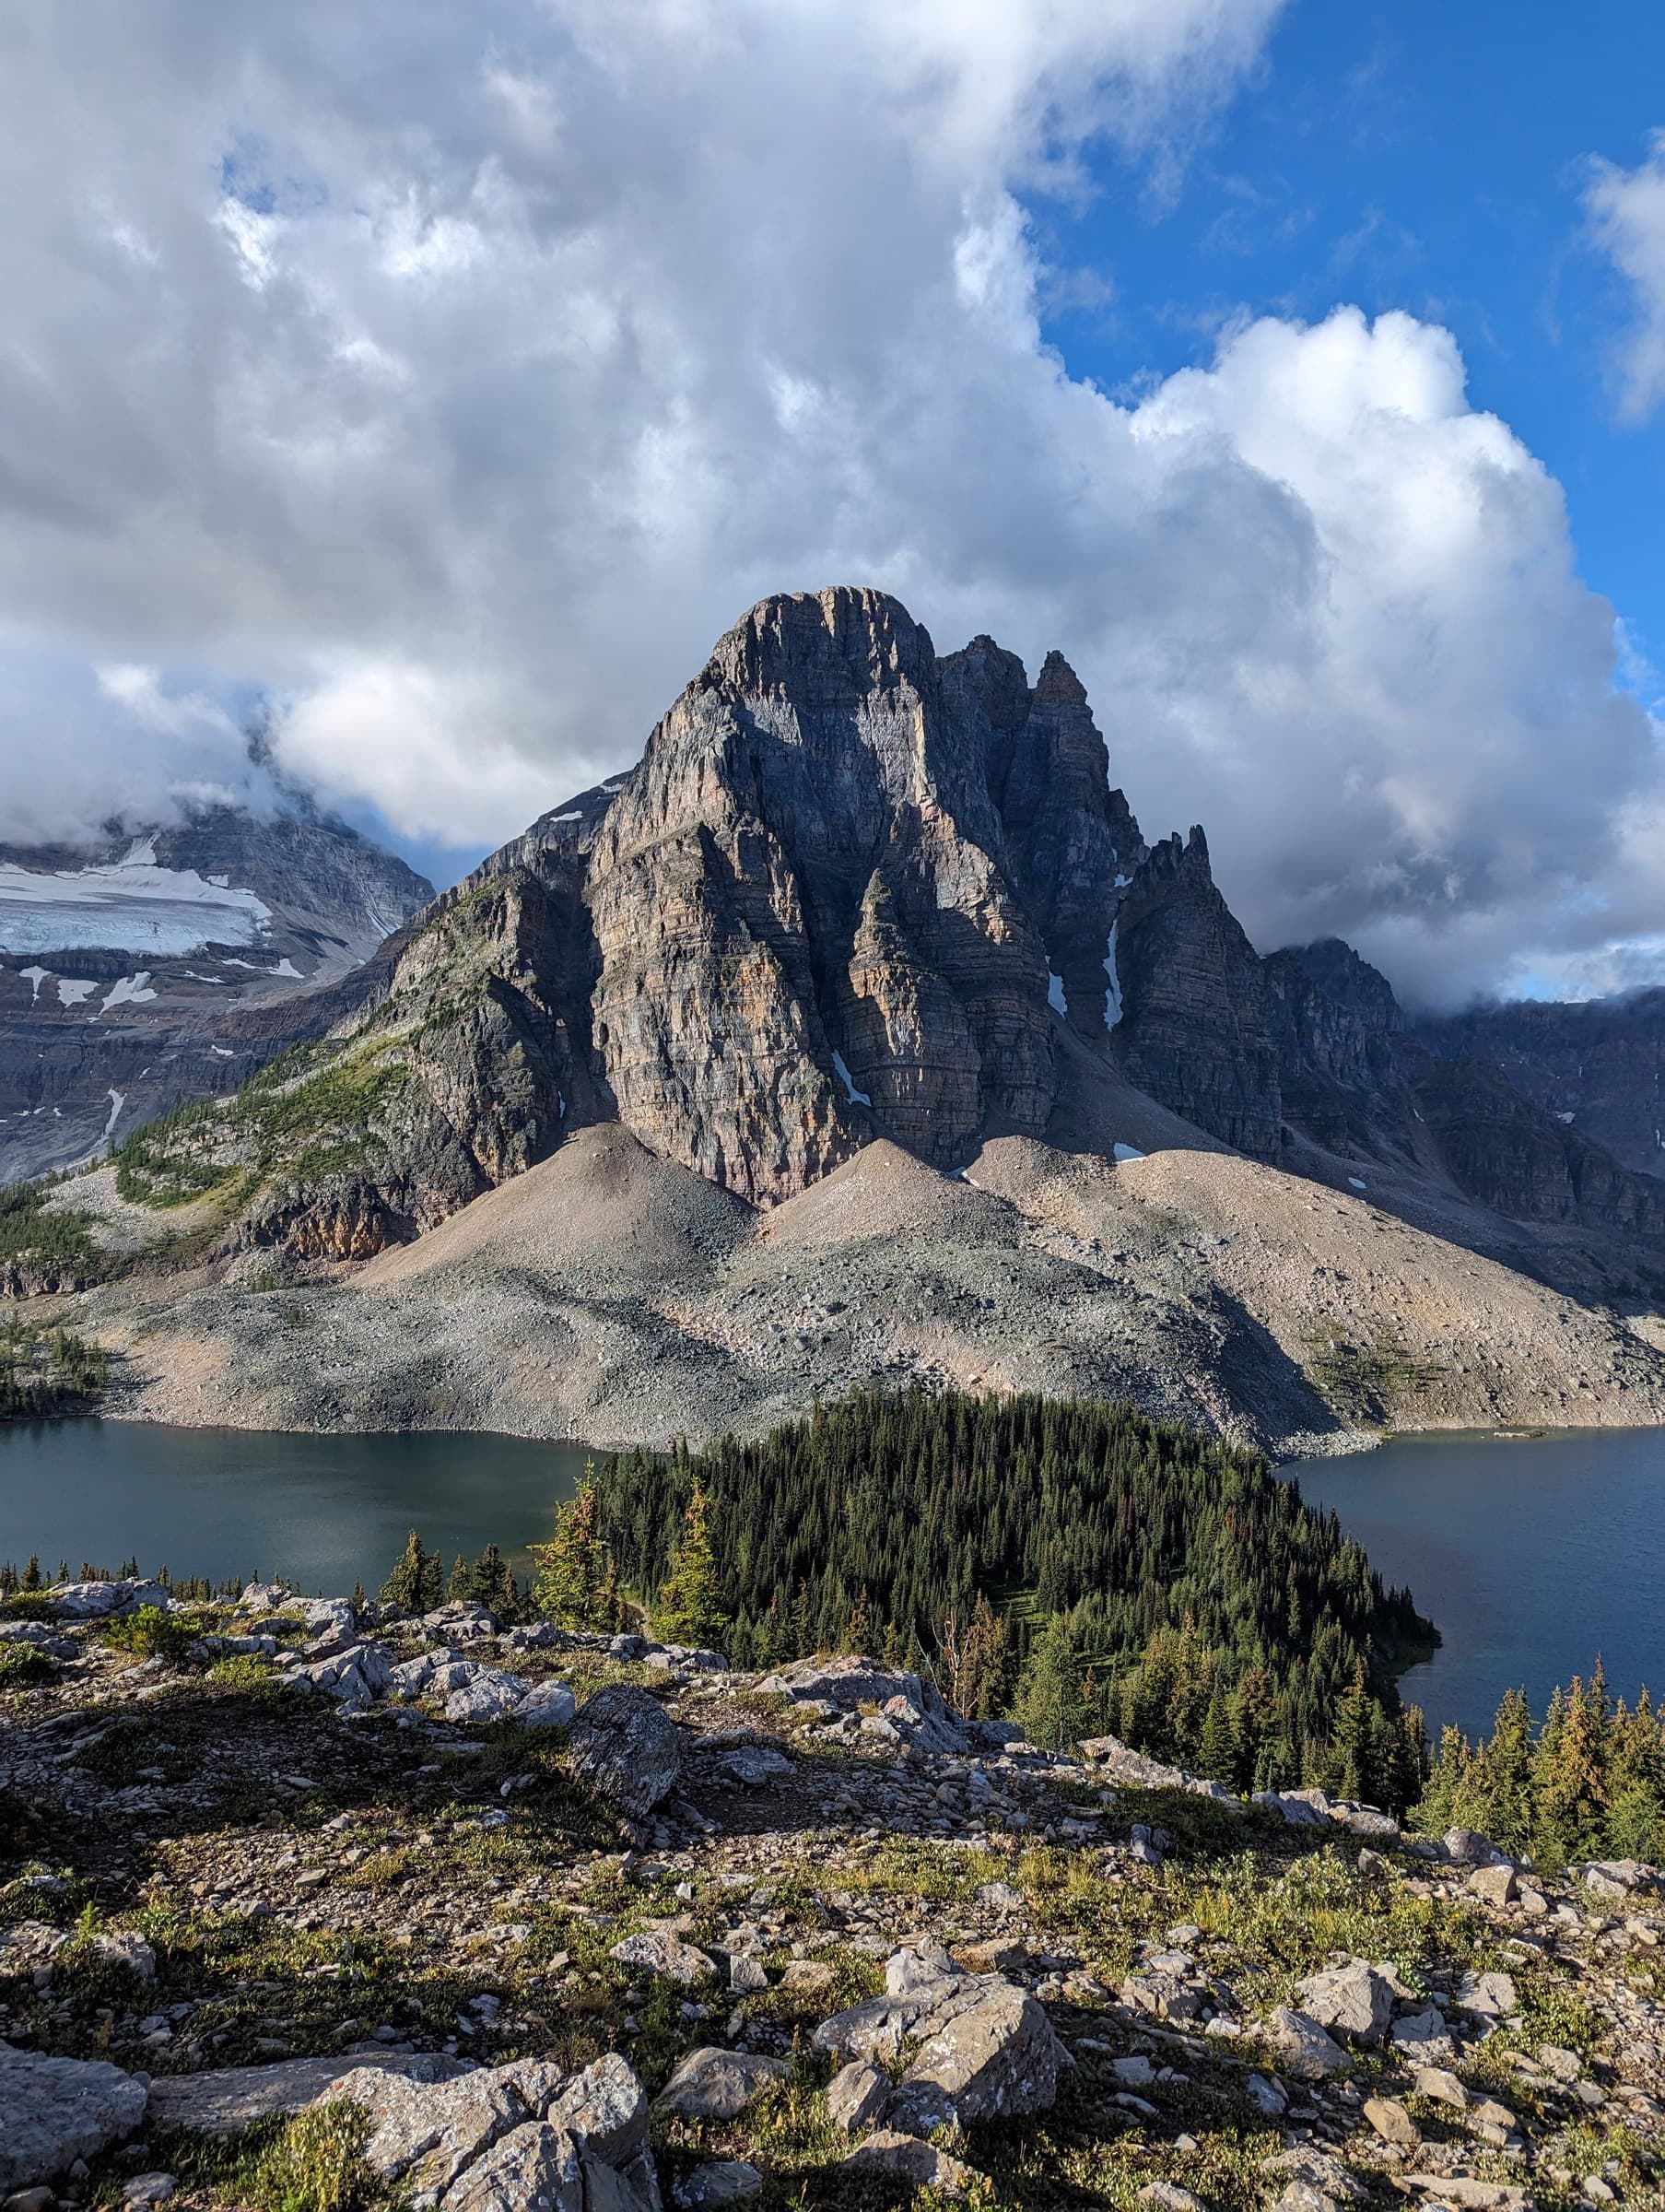
Mount Robson · 3,954 m
The team
WATonomous
Building Waterloo's first autonomous taxi.
- Division
- Autonomous software
- My team
- Lane segmentation
- The goal
- A self-driving taxi
WATonomous is a student design team at the University of Waterloo, and we're working on something I still can't quite believe I get to be part of: Waterloo's first autonomous taxi.
What I work on
Teaching the car where the lanes are.
I'm on the autonomous software division, in the lane segmentation team. We take what the car's cameras and LiDAR pick up and turn it into an understanding of the road: where the lane boundaries are, and what the markings painted on it mean.
It sounds simple until you try it. The car has to know where it's allowed to drive before it can decide how to get anywhere.
I'm still new to all of this, and right now I'm learning about as fast as I can. Honestly, that's my favourite part.
In
Camera + LiDAR
We find
Lane boundaries & road markings
So there's
Somewhere the car knows it can drive
Why autonomous driving
A car that sees the road, makes its own decisions and drives itself, all with software. I still think that's incredible.
I've been fascinated by self-driving cars for a long time, and riding in a Tesla while it drove itself made it real for me.
The whole ride I kept wondering what was actually going on inside it. How does it know what it's looking at? How does it decide what to do next? Watching it work wasn't enough. I wanted to understand it, and that's why I joined WATonomous.
Why robotics
AISoftwareThe real world
What I love about robotics is that it brings together AI, software engineering and the physical world.
In a purely software project, the world stays inside the computer. In robotics it doesn't. The environment is messy, the sensor data is never quite perfect, and an algorithm only really counts once it turns into something the machine actually does.
Where I want to take it
What I want to explore next.
- 01
Computer vision
Getting machines to understand what they see. Lane segmentation is my first real taste of it, and I want to go a lot deeper.
- 02
Autonomous systems
How seeing, planning and control all fit together into something that can move through the world on its own.
- 03
Reinforcement learning for robotics
Eventually, robots that learn how to act by trying things in the real world. Embodied AI is where I'd love to end up.
I'm only at the start of this, and I can't wait to see where it goes.
The range · 03 · Canadian Rockies
Berg Lake Trail
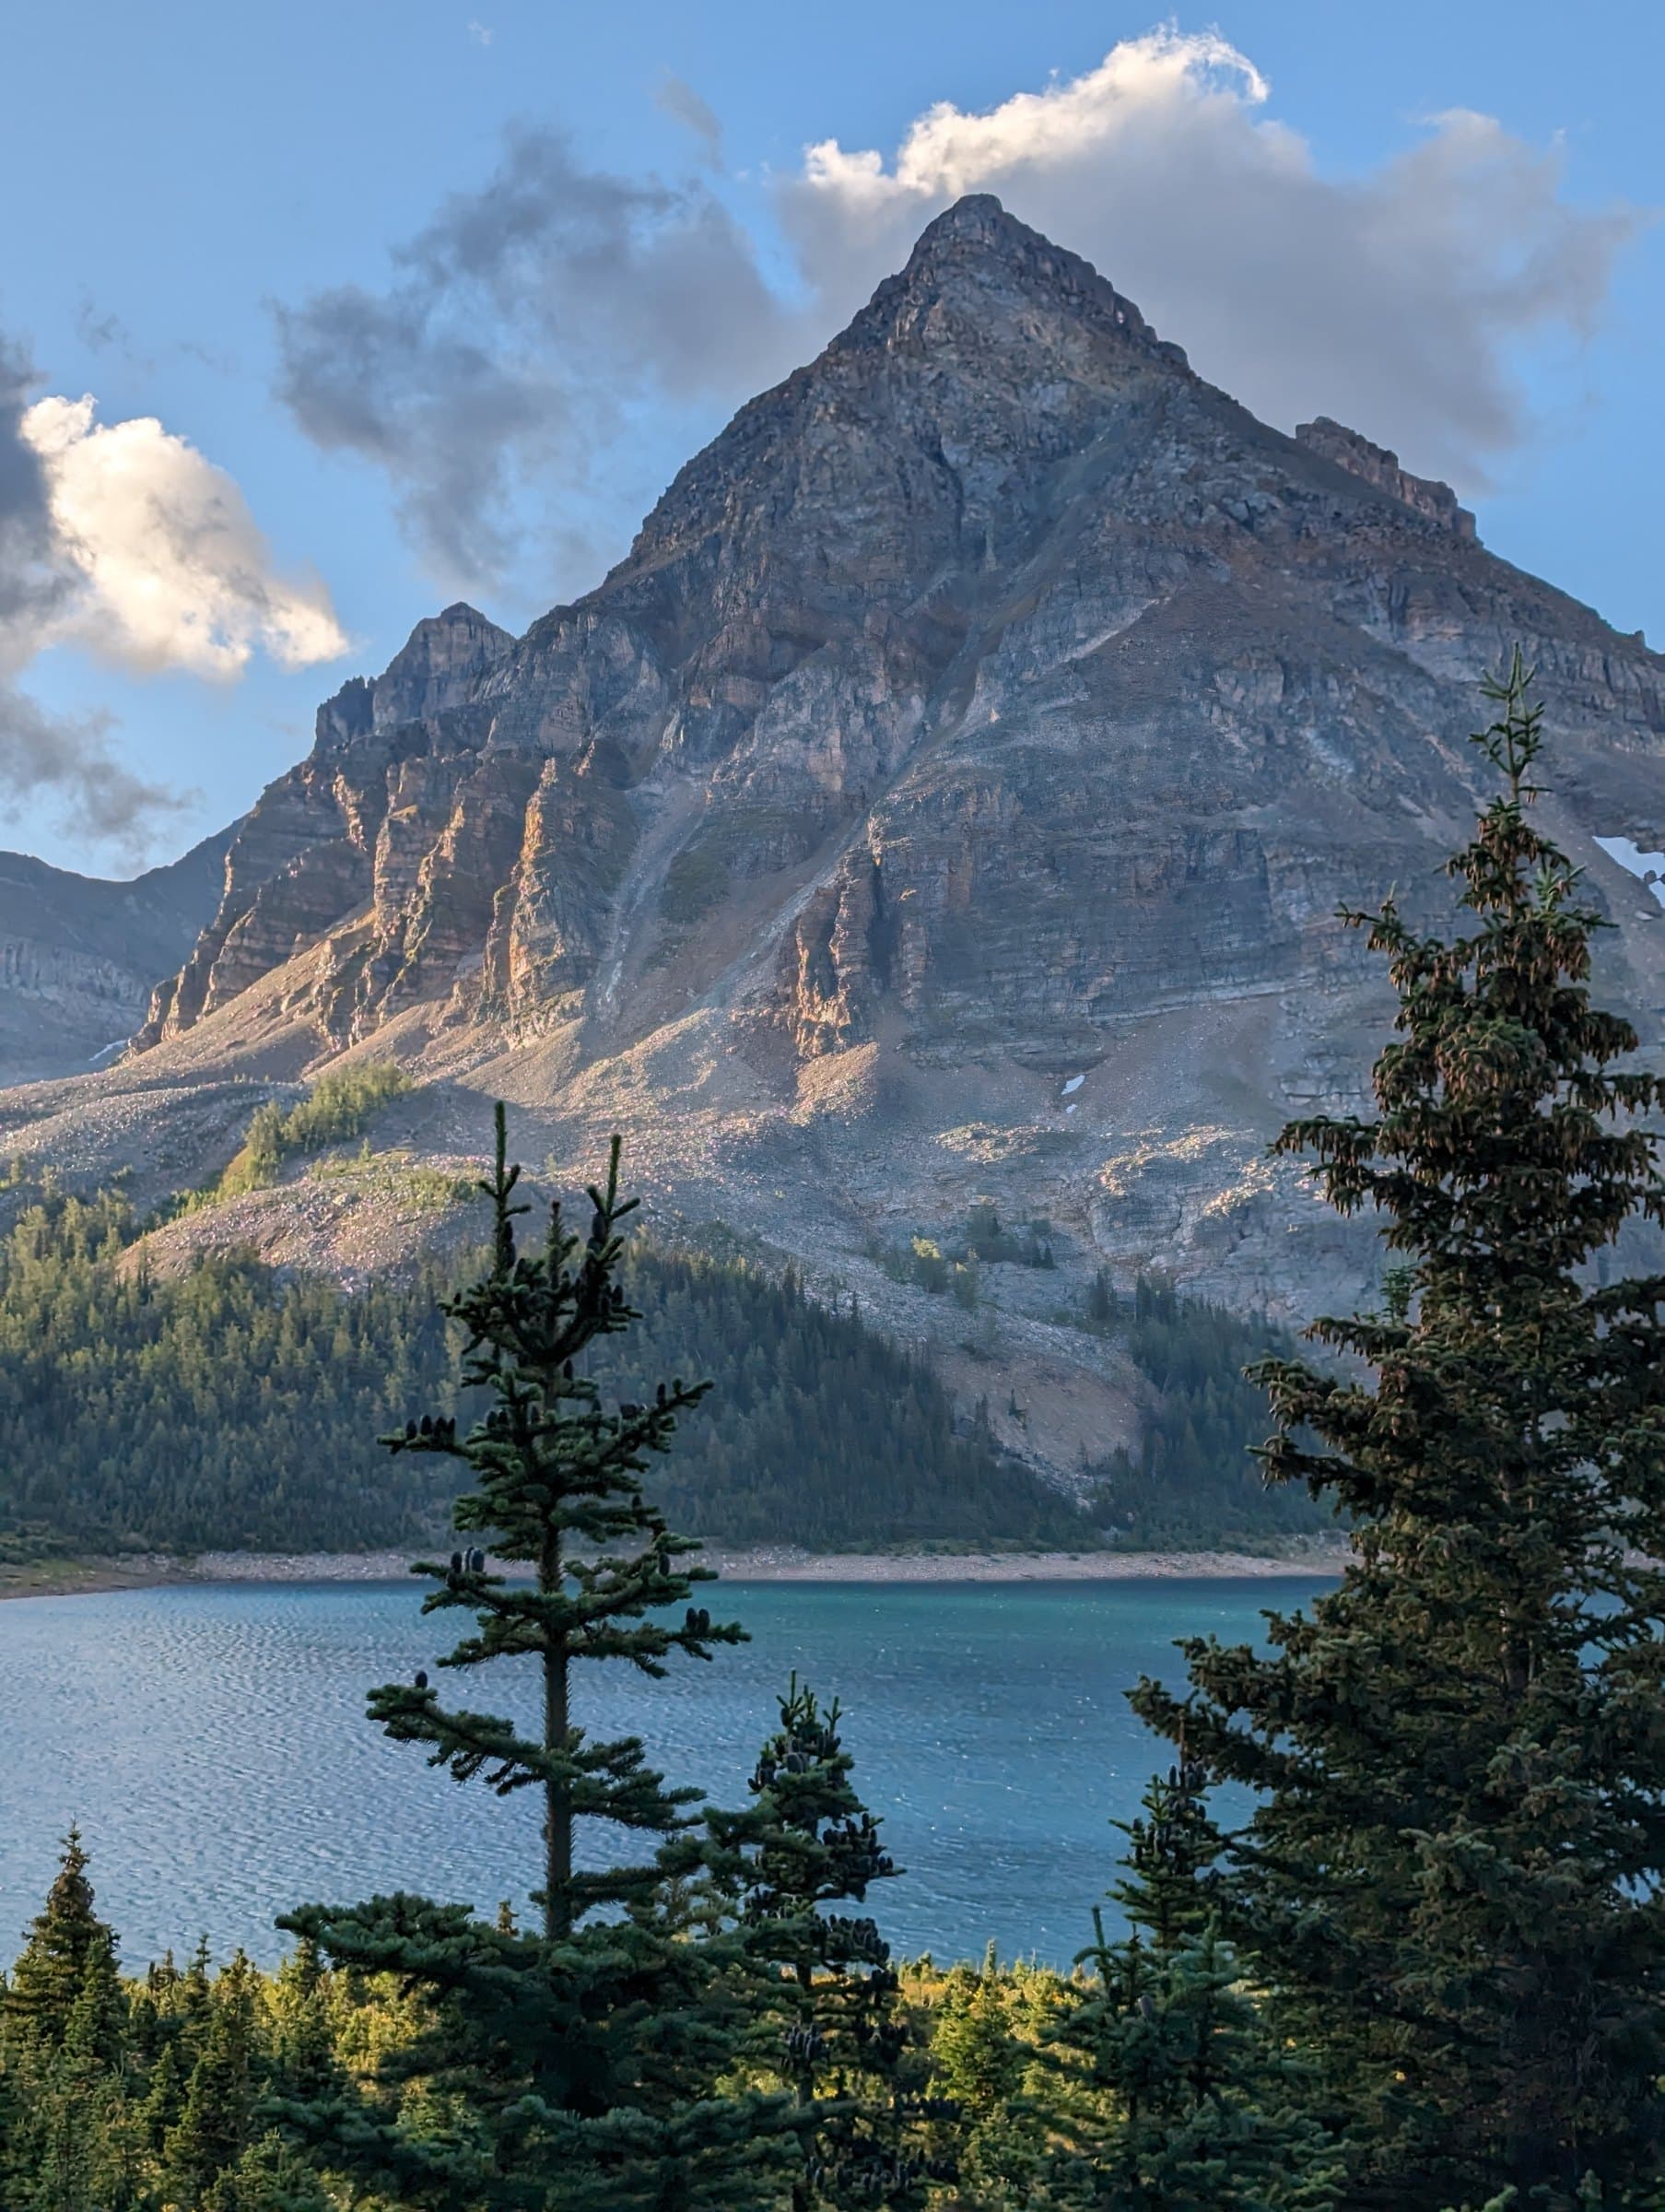
Recently my family went to the mountain ranges of western Canada. We skipped the big-name, expensive places like Banff and went to ones that are less well known but just as pretty, like Mount Robson and Mount Assiniboine.
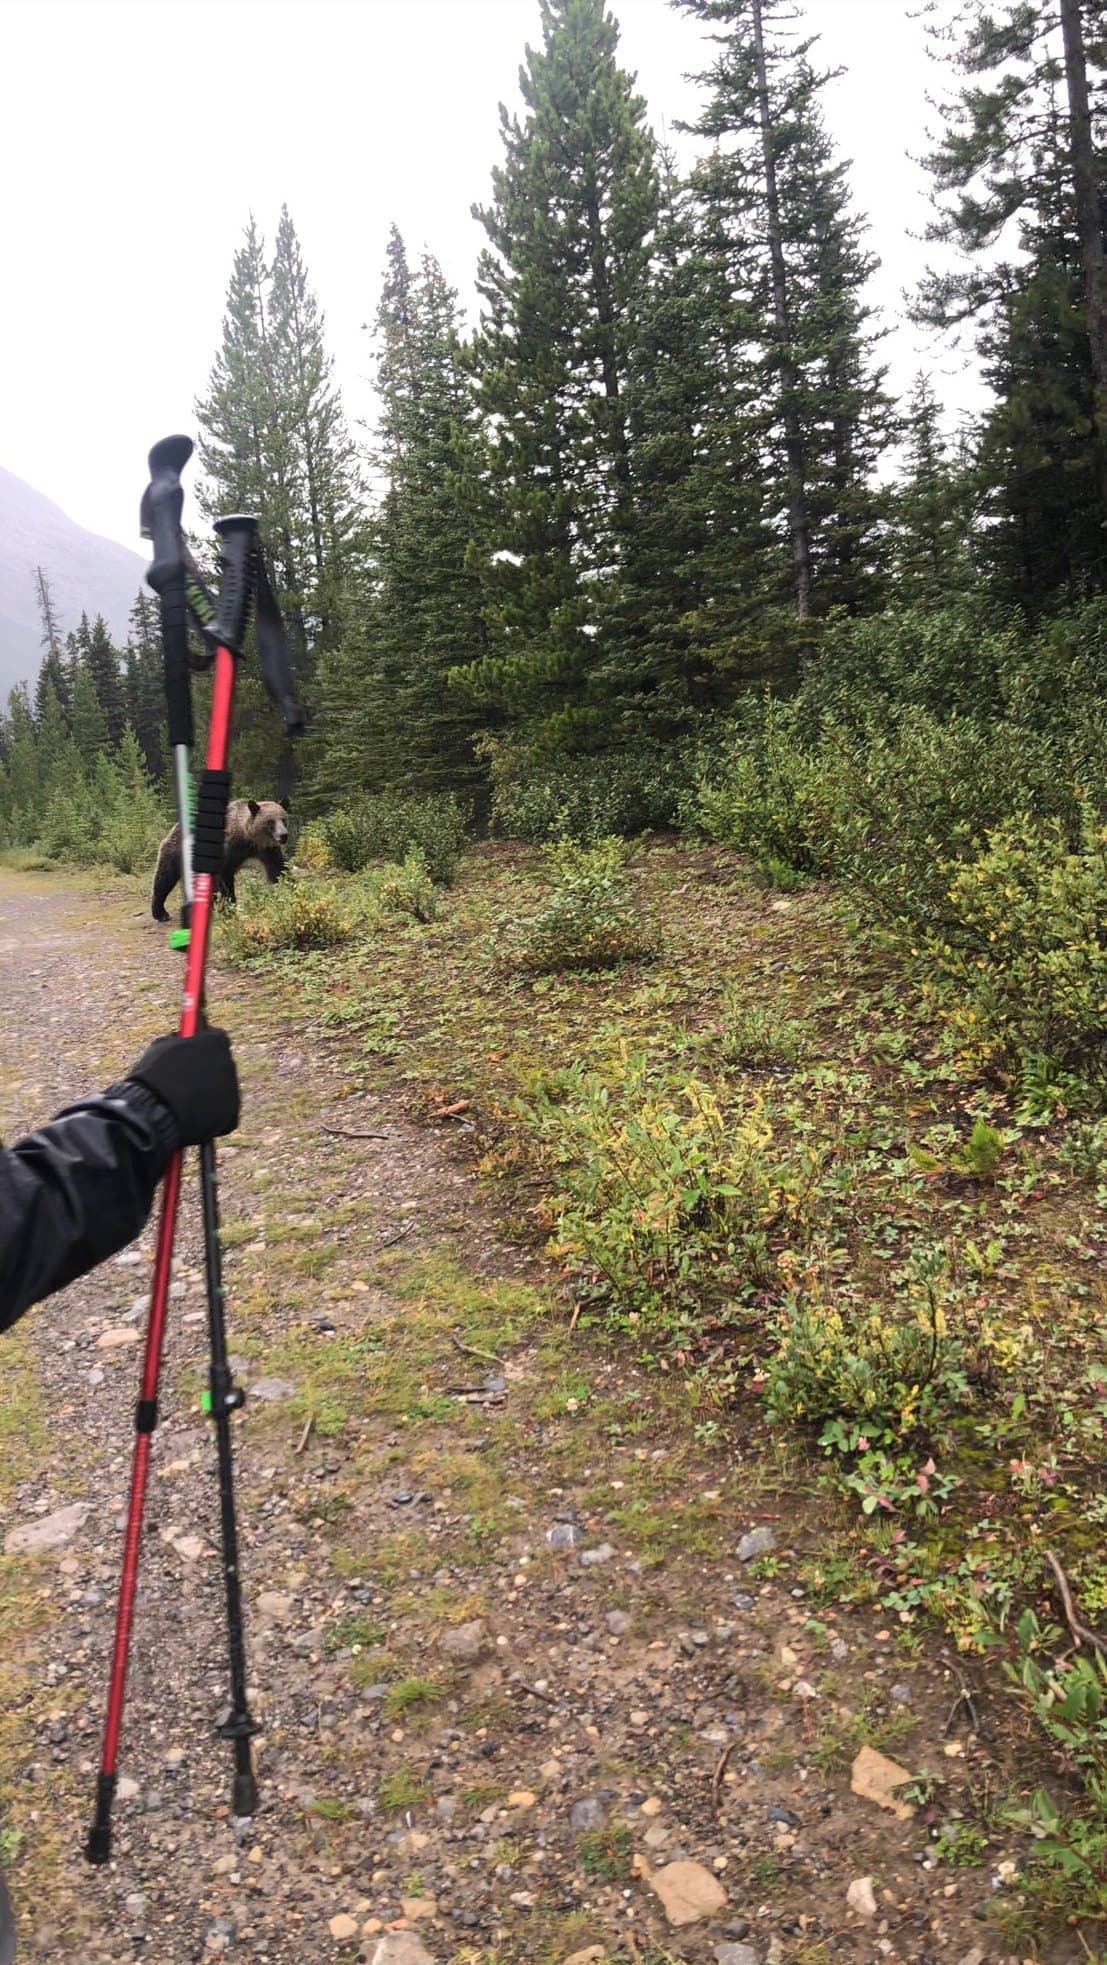
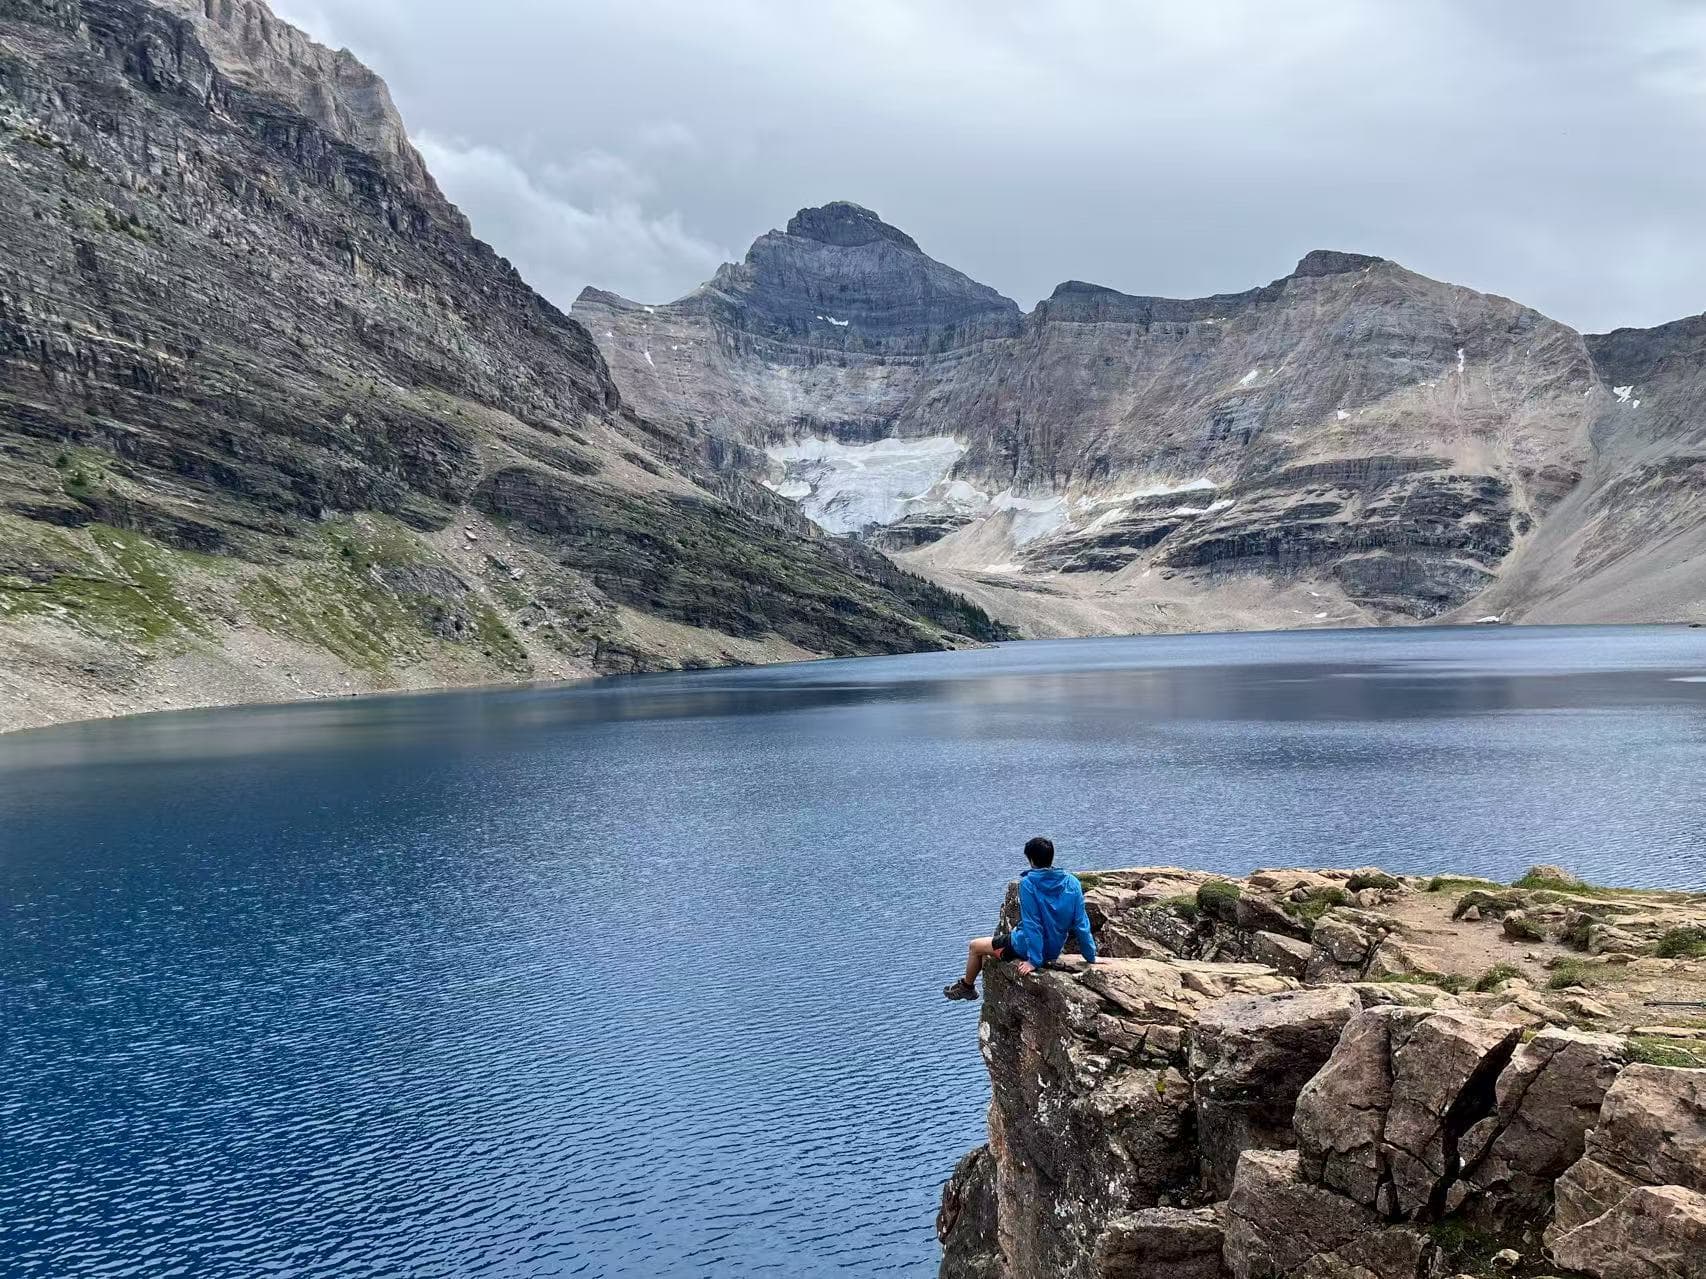
We hiked a lot of trails there, and the views were incredible. It was amazing to see that much of my home country up close.
One of them was the Berg Lake Trail. It climbs past Kinney Lake and up the Valley of a Thousand Falls to Berg Lake, right below the north face of Mount Robson, the highest peak in the Canadian Rockies.
- trailhead to Berg Lake
- 19 km
- trailhead to Berg Lake
- climb to the lake
- 800 m
- climb to the lake
- Mount Robson
- 3,954 m
- Mount Robson
- parks: Robson and Assiniboine
- 2
- parks: Robson and Assiniboine
From the trail